Simulation Is Back: Scaling Contact-Rich, Long-Horizon Manipulation
Supporting the below United Nations Sustainable Development Goals:支持以下聯合國可持續發展目標:支持以下联合国可持续发展目标:

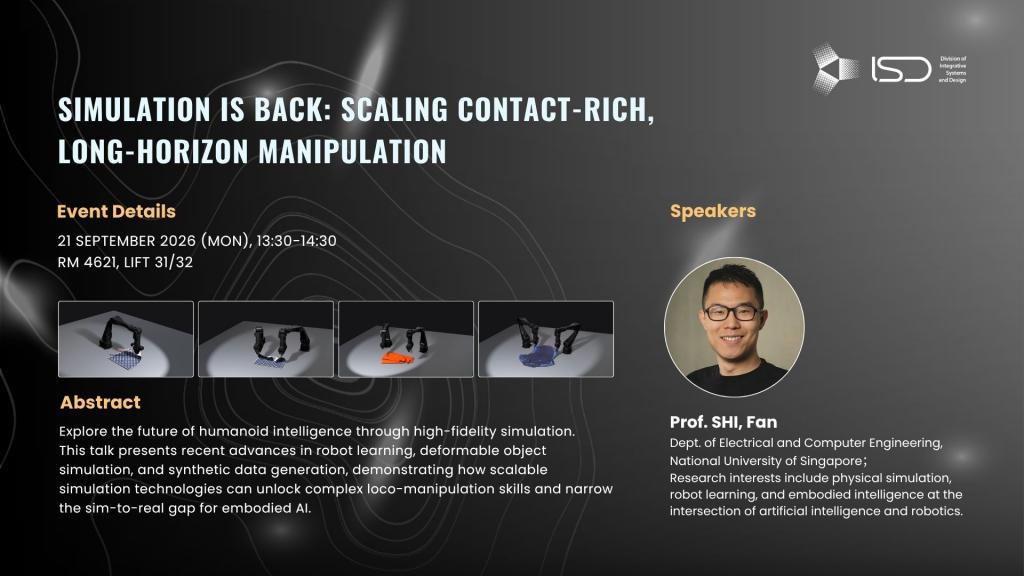
Robot learning fundamentally depends on access to abundant, high-quality, and low-cost data. Humanoid robots present unique challenges and opportunities—combining locomotion over rigid terrains (mostly) with manipulation of diverse, often deformable, objects. While synthetic data has driven remarkable progress in locomotion through deep reinforcement learning, manipulation remains limited by data scarcity and simulation fidelity. In this talk, I will discuss our recent advances in simulation technology inspired by our breakthroughs in computer graphics, aimed at enabling more effective humanoid learning for complex loco-manipulation tasks. Our new simulation engine delivers significant improvements in both speed and accuracy for deformable object dynamics, unlocking a wide range of contact-rich tasks previously deemed infeasible. I will conclude by outlining how these advances may shape the next frontier of humanoid intelligence, where realistic synthetic data bridges the gap between simulation and the real world.
Fan Shi is an Assistant Professor at the National University of Singapore, where he holds the prestigious NUS Presidential Young Professorship. His research lies at the intersection of artificial intelligence and robotics, with a focus on physical simulation, robot learning, and the development of scalable methods for embodied intelligence. His work has been recognized through awards and support from leading organizations, including the NVIDIA Academic Grant Program, Google Research, and the Swiss AI Initiative.